


Jimmy Paputto
L1/L5 GNSS RTK HAT
L1/L5 GNSS RTK HAT
Regular price
2.099,00 zł PLN
Regular price
Sale price
2.099,00 zł PLN
Taxes included.
Quantity
Couldn't load pickup availability
Full guide for this HAT
L1/L5 GNSS RTK HAT for Raspberry Pi
A professional-grade, high-precision GNSS RTK HAT based on the u-blox NEO-F9P module. Designed for developers, enthusiasts, hobbyists and industrial users. This board provides centimeter-level positioning using dual-band L1/L5 GNSS and RTK, making it ideal for robotics, drones, outdoor navigation and autonomous systems.
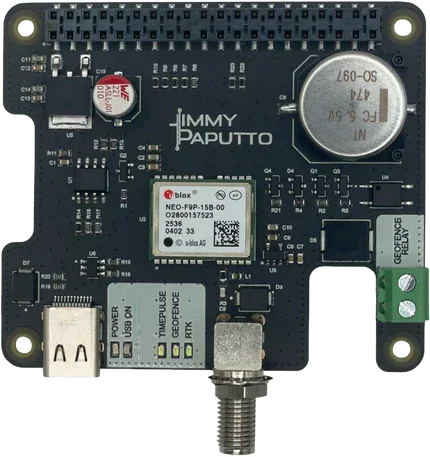


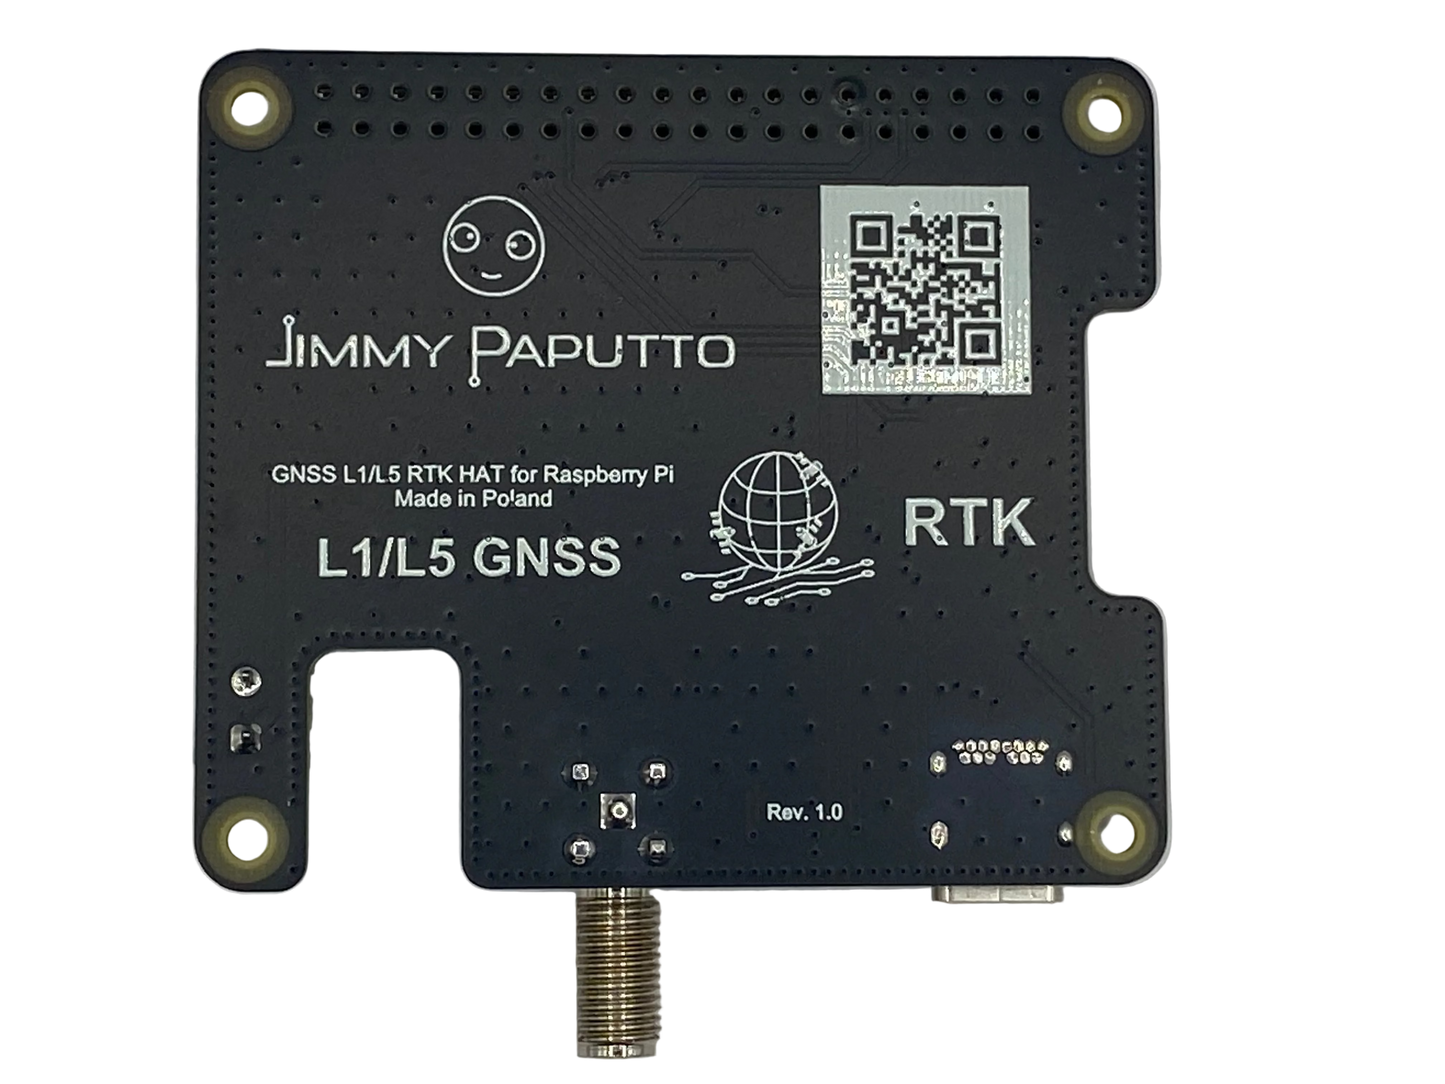
You will also need an antenna
L5 only helps if the antenna receives it. This u-blox antenna covers L1 and L5 and comes with a 5 m cable.
 u-blox dual-band L1/L5 antenna
ANN-MB1-00
299,00 zł
View antenna
Specifications
Key Features
-
Dual-Band GNSS (L1/L5): Simultaneous reception of GPS, Galileo, GLONASS, and BeiDou with advanced multipath mitigation, jamming and spoofing detection.
Position accuracy:- RTK Fixed: up to 2 cm
- RTK Float: centimeter-to-decimeter level
- Standalone GNSS: 2m CEP
- RTK Base / Rover Support: Configurable as an RTK base station or rover. Supports RTCM correction streams via SPI, USB, or network-based correction services (NTRIP).
- SPI Communication: Fast, low-latency SPI interface for Raspberry Pi, supporting high update rates up to 25 Hz (7 Hz RTK Fixed) for real-time positioning and control loops.
- Survey-In Mode: Automatic base station position averaging for accurate RTK base configuration.
- Geofencing: up to 4 circular zones
- Geofence Relay Output: Trigger devices or alerts based on configurable geo-location zones.
- Hot Start Capability: Onboard supercapacitor allows hot-start procedure (2 seconds to acquire fix) up to 4h after power loss
- USB-C Interface: Direct access to the u-blox module for configuration, debugging, and data streaming. Compatible with u-center and open-source GNSS tools.
- External Antenna Support: SMA connector with 3,3 V active antenna power supply. Optimized for dual-band L1/L5 GNSS antennas.
- Open-Source Software: GitHub repo with user-friendly library with many examples, link: https://github.com/jimmypaputto/gnsshat
- Full guide: installation, first fix, configuration, API reference for C++, C and Python, and examples for every feature at docs.jimmypaputto.com/gnss-hat
Applications
- Robotics & autonomous navigation
- Sensor fusion with PPS
- Precision agriculture & surveying
- Geofencing security systems
- Mobile mapping & geospatial data collection
- Drones, UAVs, UGVs & autonomous vehicles
- Outdoor tracking and telemetry
- Research & GNSS experimentation
ROS 2
- Own topic with everything: /gnss/navigation carries position, accuracy, DOP, satellites, RF status and geofence state.
- Standard topics: /gps/fix (sensor_msgs/NavSatFix) and /gps/vel, so nav2 and robot_localization work without glue code.
- RTCM3 as topics: the base publishes corrections on /gnss/rtk/corrections and the rover subscribes to them. Pick base or rover in one YAML file and DDS does the rest.
- NTRIP and existing setups: with the optional NTRIP bridge the same corrections also flow as rtcm_msgs/Message on /rtcm, so an NTRIP client or caster you already run in ROS plugs straight in.
- Runtime reconfiguration: change rate, dynamic model or RTK mode through /gnss/set_config without restarting the node.
Package Includes
- 1x GNSS RTK HAT for Raspberry Pi (u-blox NEO-F9P based)
- Mounting distances and screws
- GPIO header for Raspberry Pi